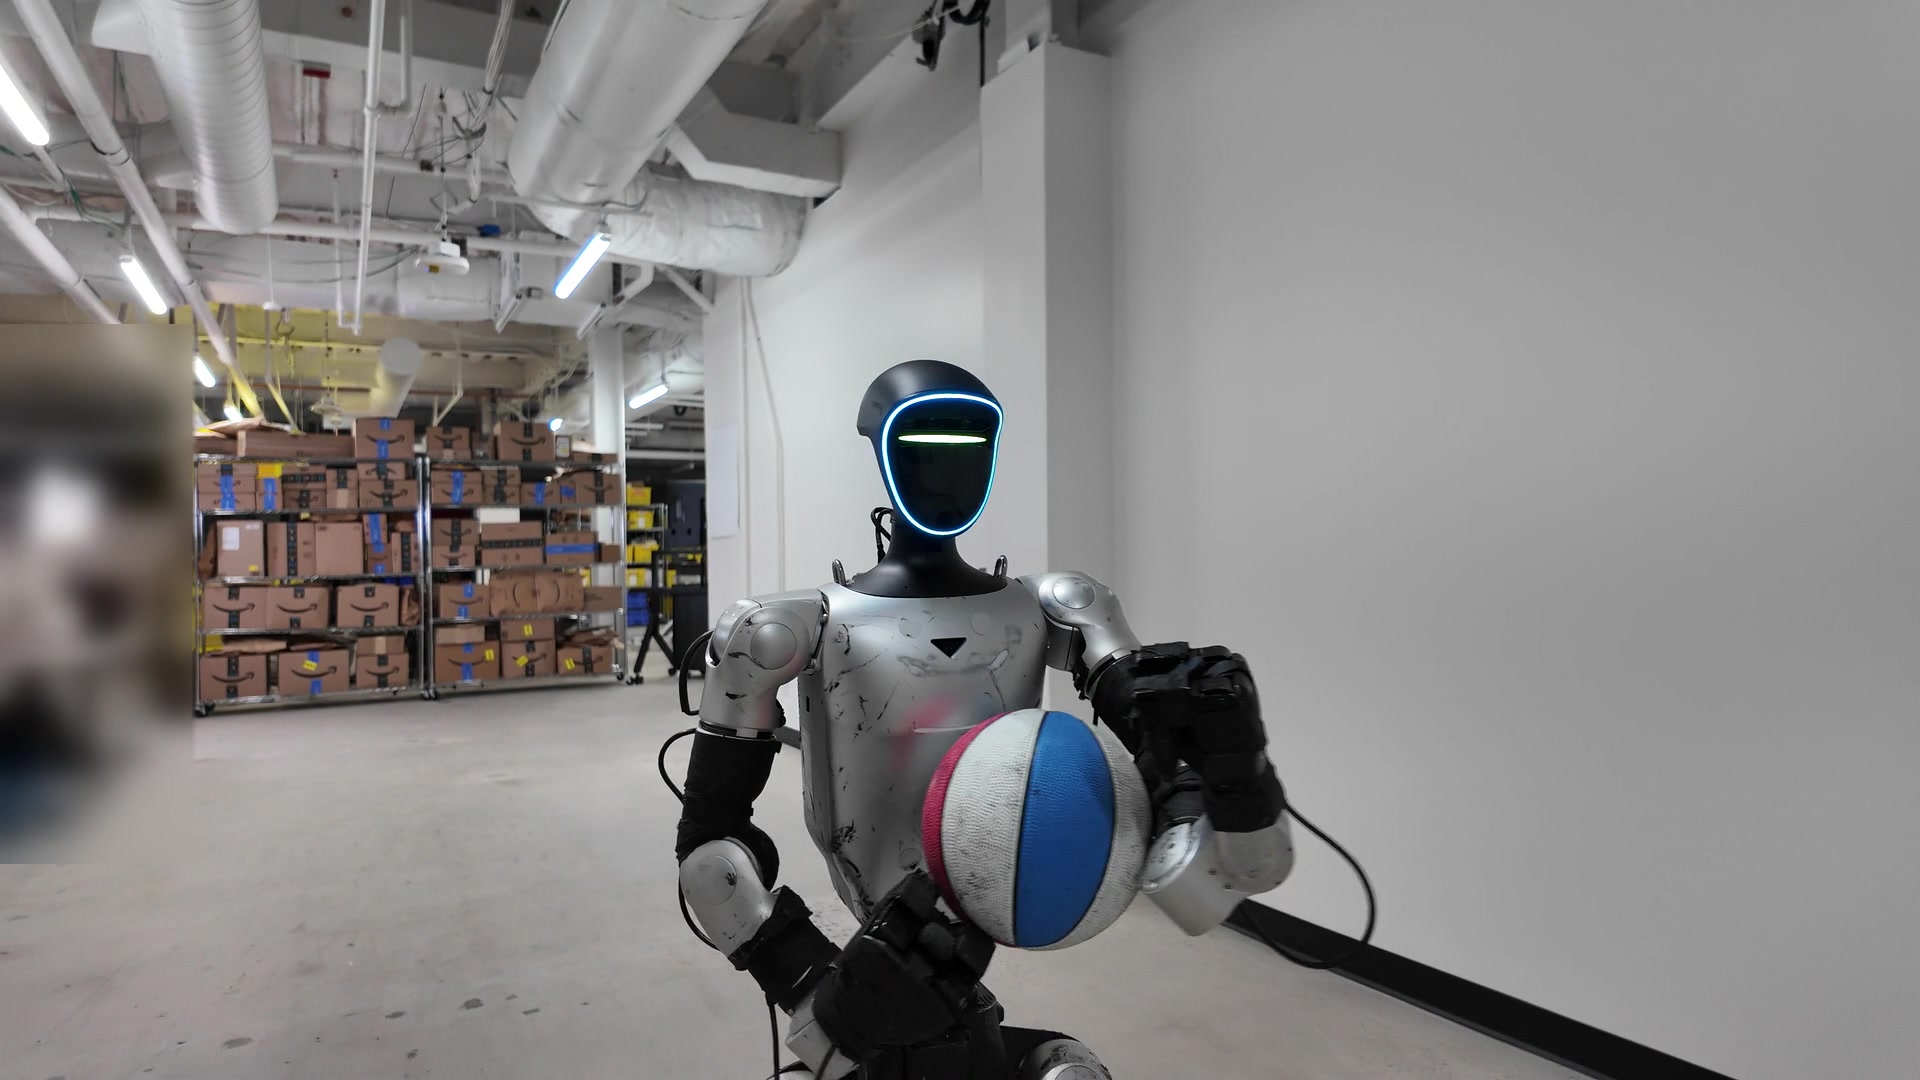
Whole-Body Dexterity gives Unitree G1 more ways to hold a load
A learned controller helps G1 keep a ball or box supported as it changes grip. The tests are human-guided, and the full shelf-to-table sequence succeeds in seven of ten trials.
INDEPENDENT / UNOFFICIALIndependent and unofficial. Not affiliated with, endorsed by, sponsored by, or operated by Unitree Robotics.
The complete publication record, growing one article at a time.
8 matching articles · Clear filters
A learned controller helps G1 keep a ball or box supported as it changes grip. The tests are human-guided, and the full shelf-to-table sequence succeeds in seven of ten trials.
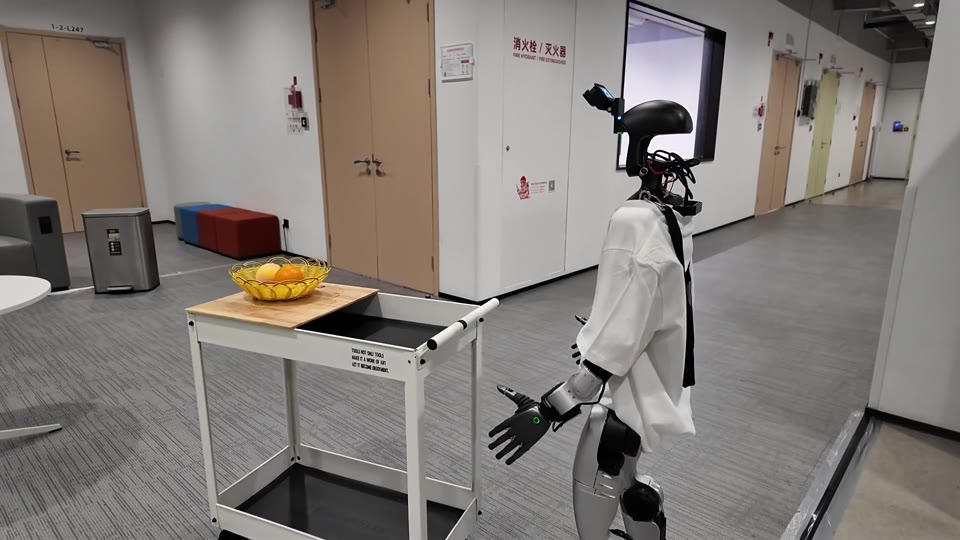
Alibaba researchers pair 500 hours of human activity with whole-body motion to train a G1 policy. Their real-world trials support the approach, while the release still stops short of a reproducible deployment.
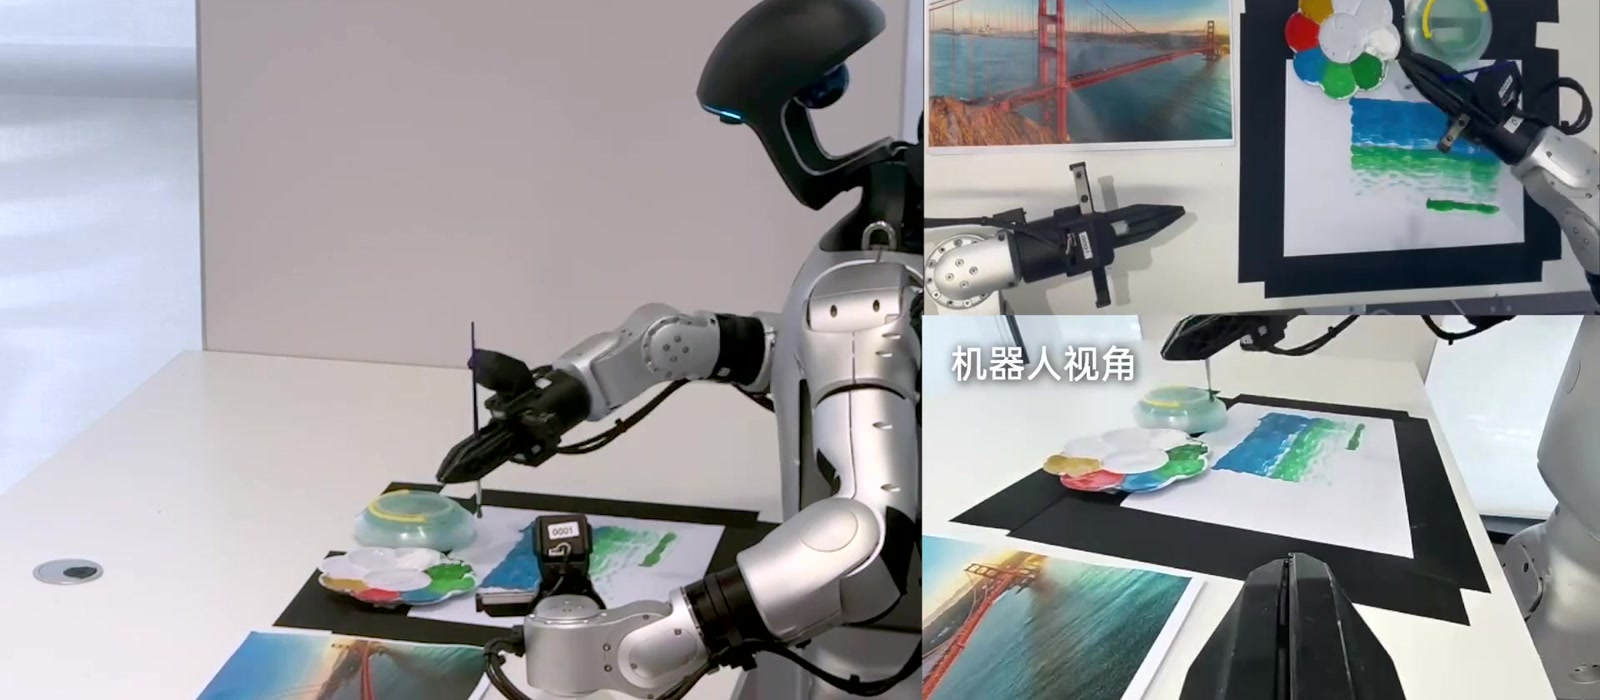
Official code now shows GPT-6 Astra coordinating four G1-D and R1-D skills through cameras, bounded tools and task instructions. The edited demos still provide no trial counts or generalisation benchmark.
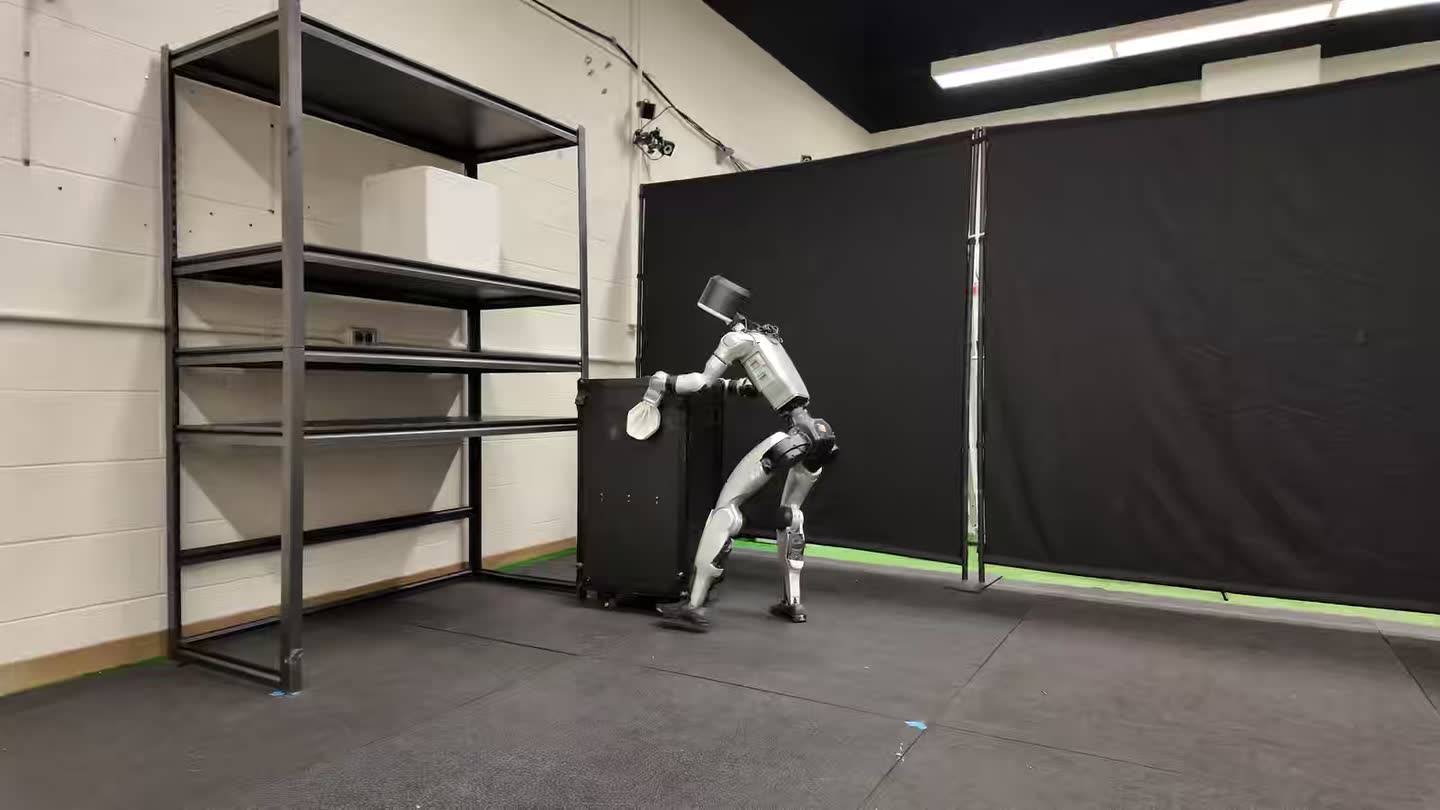
Instead of asking one policy to control every joint, Workhorse separates visual planning from whole-body tracking and connects them through five human-scale poses. The result is dynamic autonomy on a real G1—but not yet a general or open system.
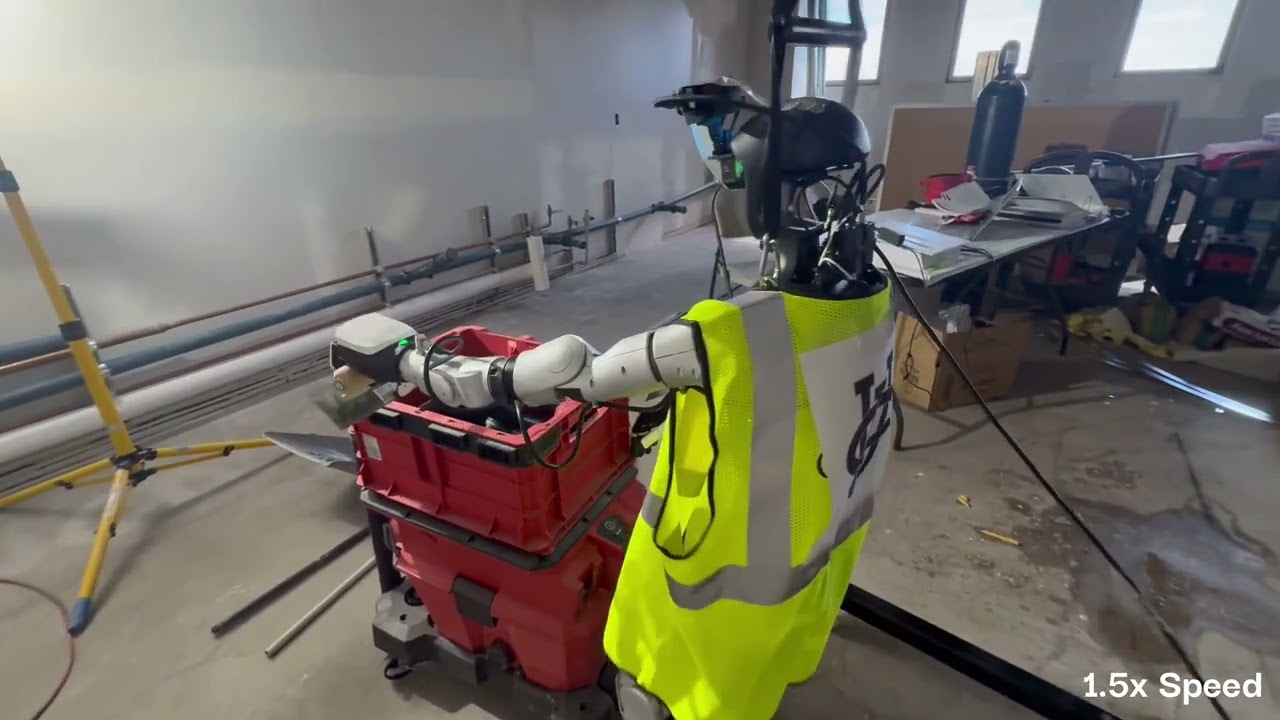
A construction-site study got G1 to carry a tool and paint a test sheet, but the clearest result was the productivity gap: about 18 times slower for transport and three times slower for painting.
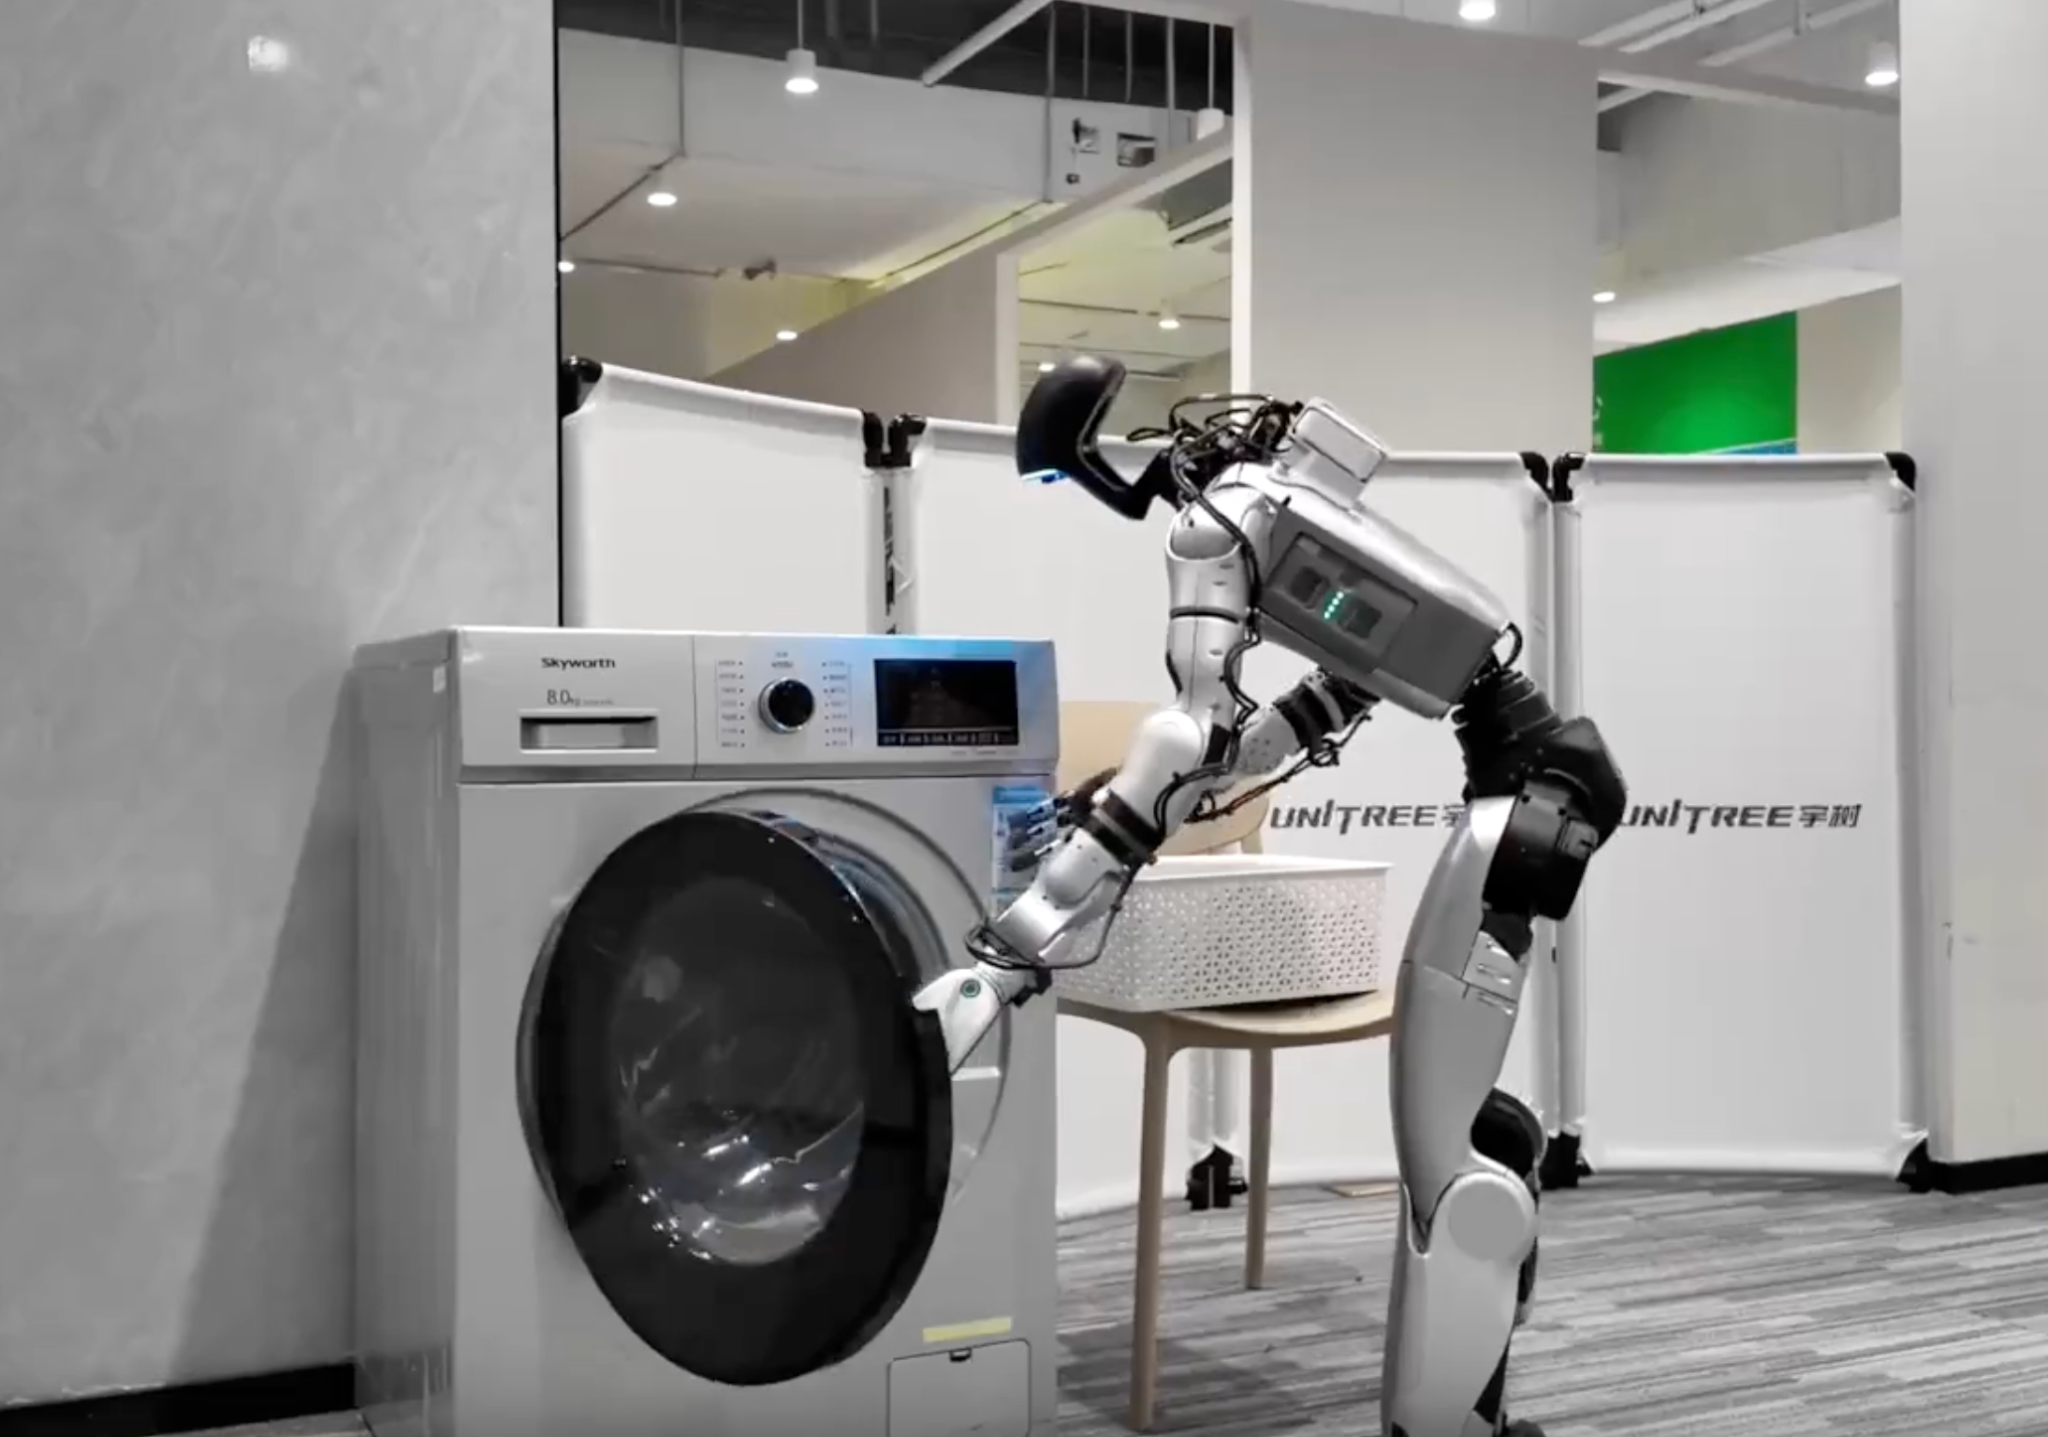
The September 20 code release makes action-expert training possible with earlier ER weights. It does not yet provide the complete WLA-Base checkpoint or a turnkey reproduction of Unitree’s robot demonstrations.
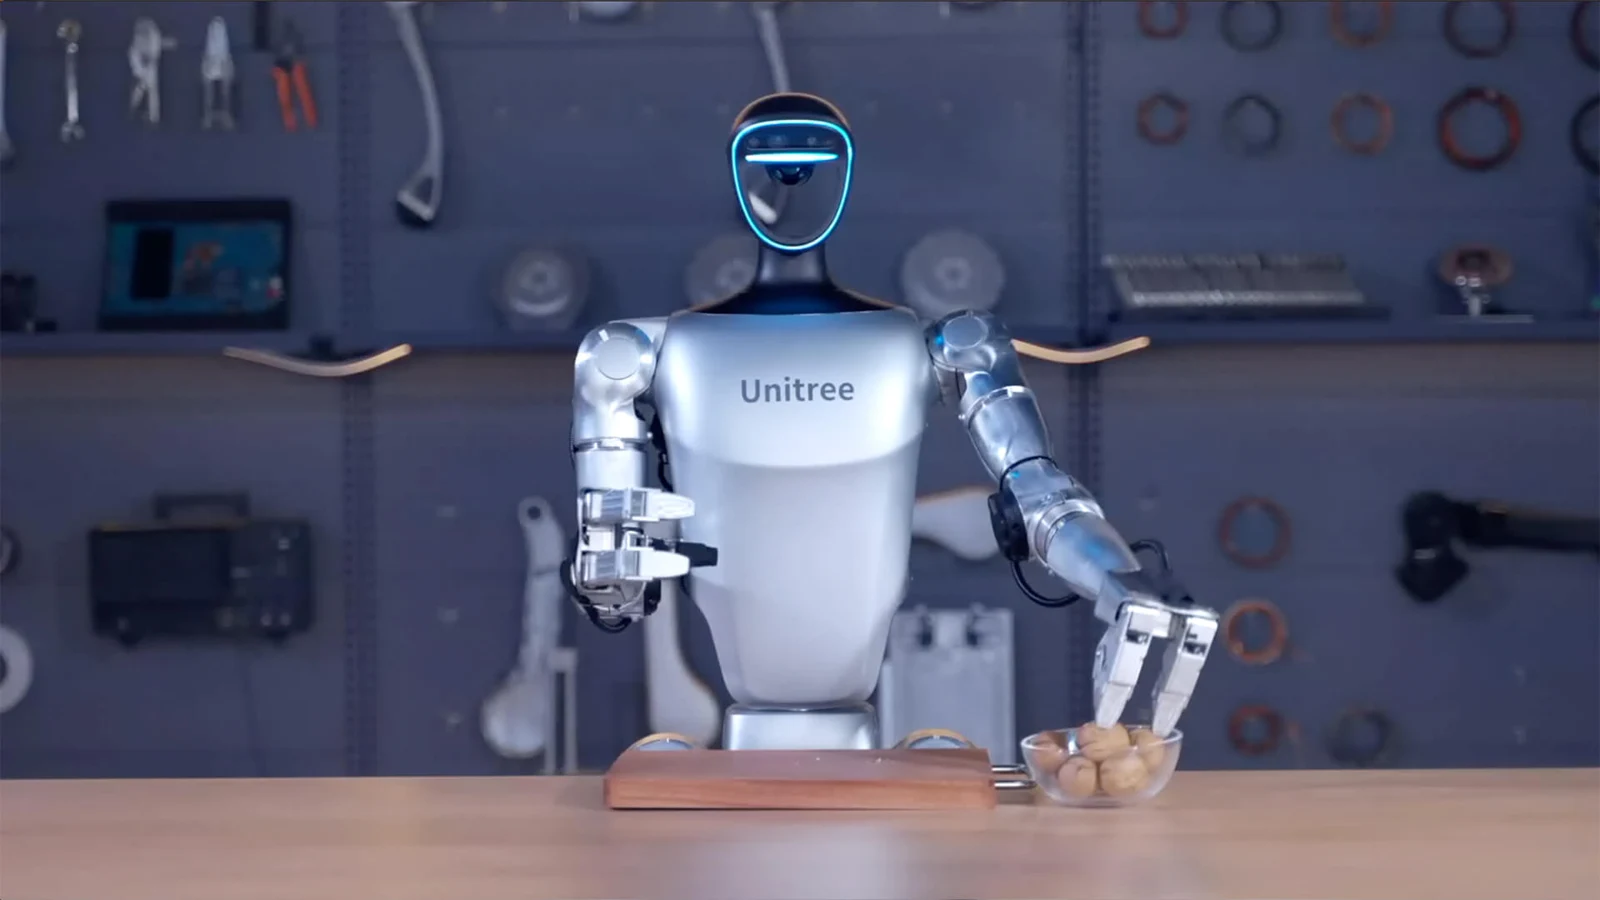
The new G1 EDU teleoperation offering puts integration, data capture and support at the centre of the pitch. Its value depends on the work it saves researchers.
20–26 August 2026 in review. Wang Xingxing described a threshold for robotics’ breakout. Turning that ambition into a useful test requires more than a percentage.